


Prototyping and R&D
Questions turned into mechanical, electronic, and control proofs of concept before discussing a product.
Robotics · product, prototype, and integration
We explore products, routes, interaction, and digital components to define which solution is worth evaluating in each context.
Robotic system
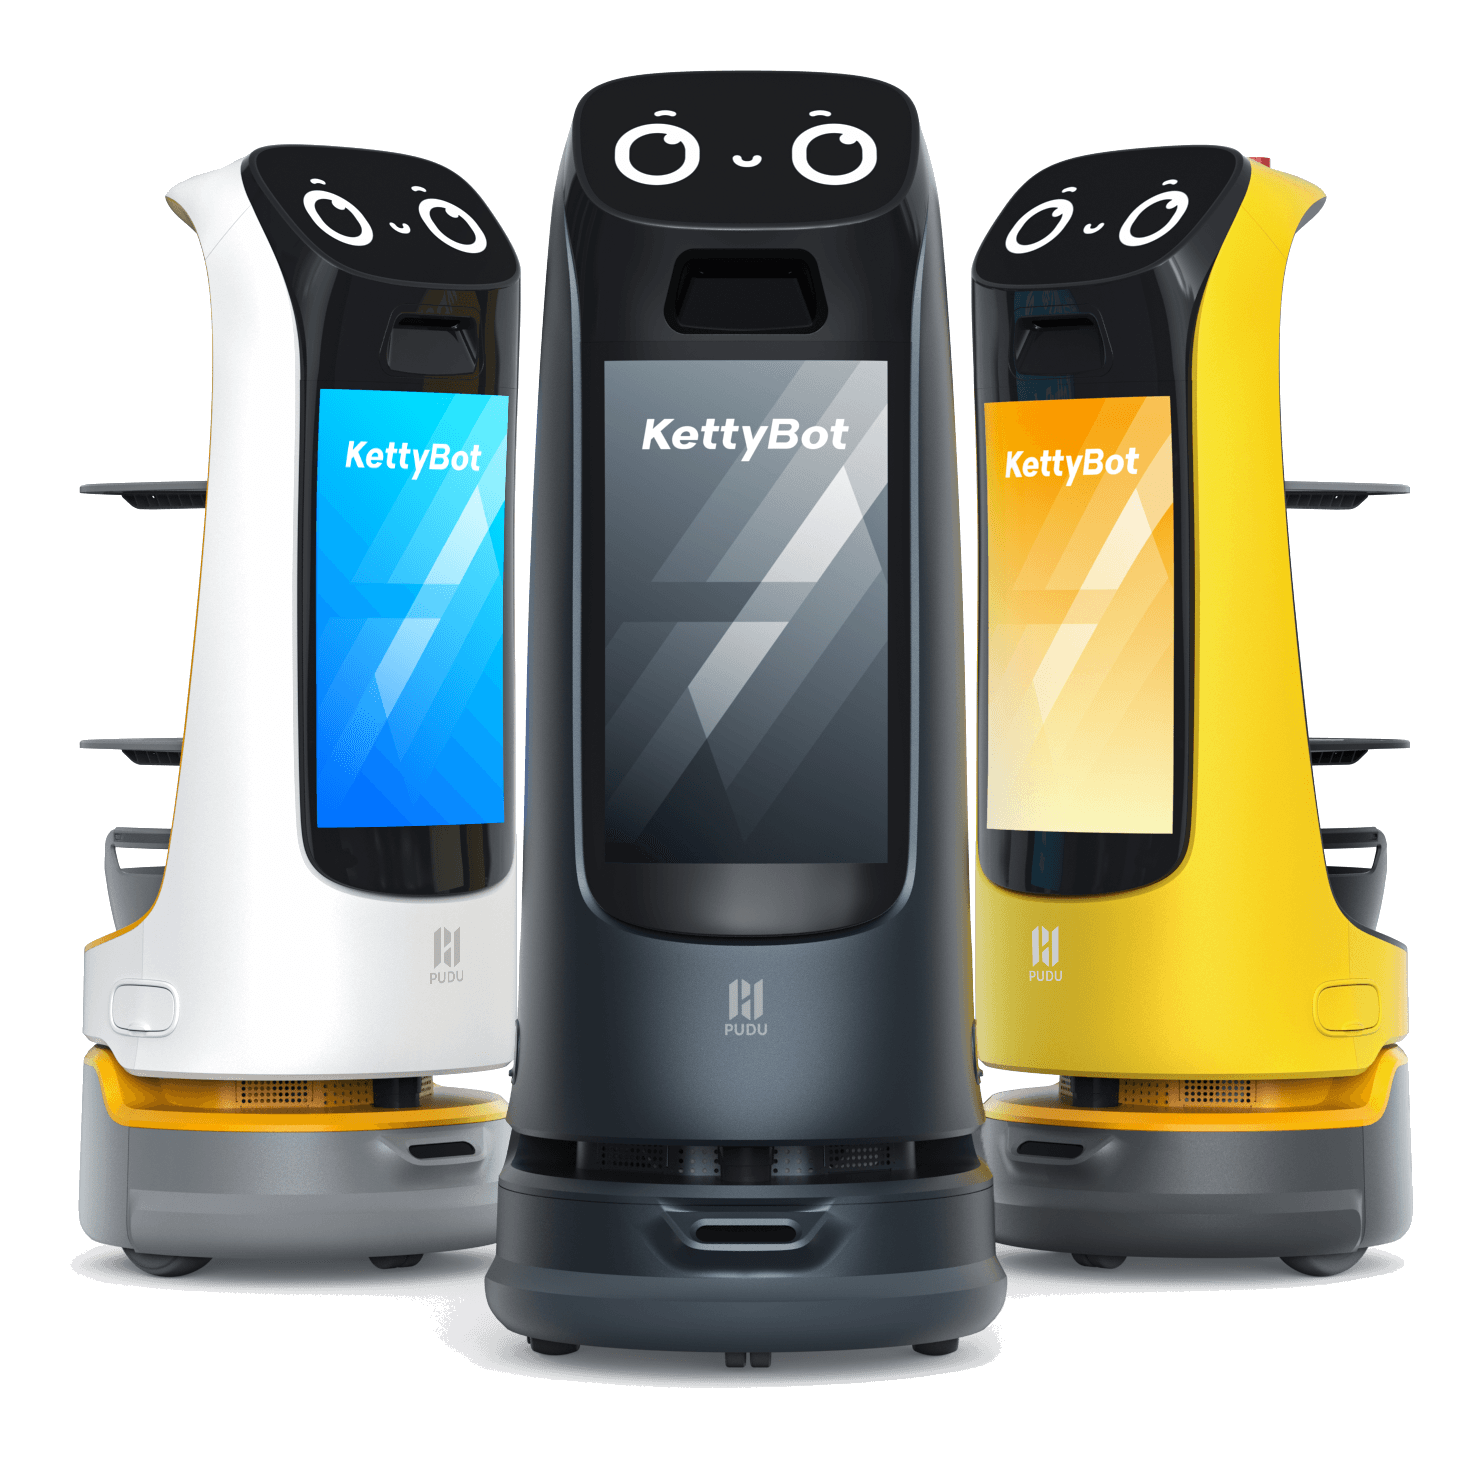
Robotics capabilities
Each project requires separating the question, product, integration, and operating conditions before defining scope.
Questions turned into mechanical, electronic, and control proofs of concept before discussing a product.
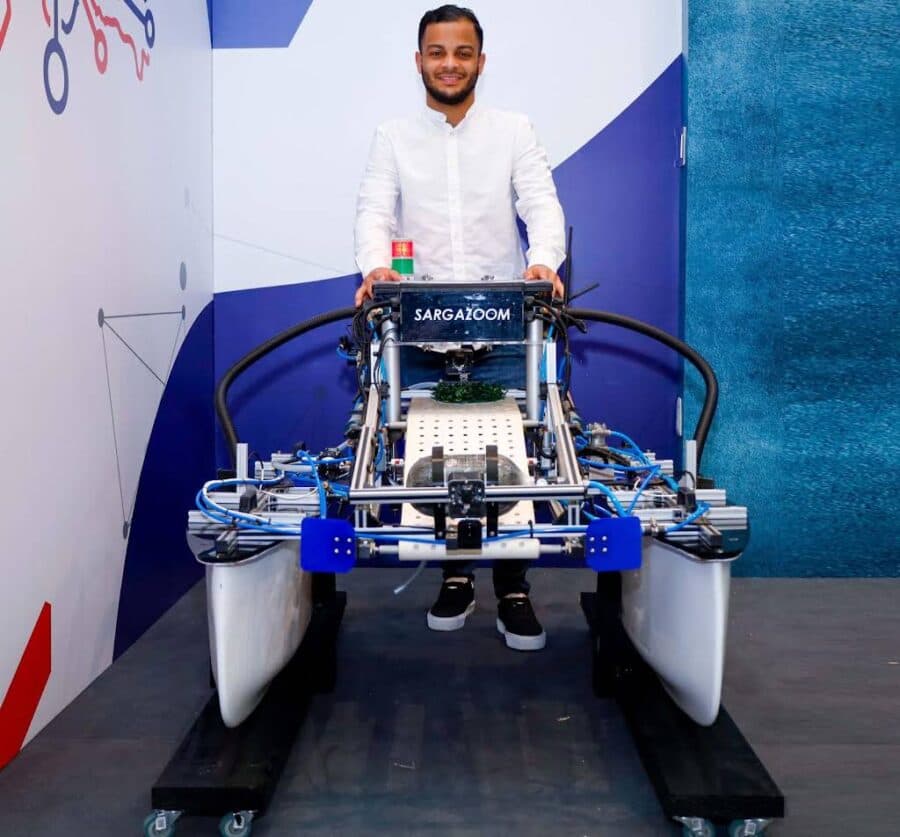
SargaZoom · own R&D prototype
SargaZoom began as the final project in Rómulo Pérez’s Mechatronics degree. It was developed as a vessel prototype for collecting sargassum, bringing mechanical structure, electronics, control, and software into one applied research effort.
ONAPI subsequently granted a utility-model patent to SargaZoom, as documented in 2025 by an INTEC institutional publication.
View institutional publicationIt is not part of the five-robot catalog. It is presented as an own R&D prototype and does not confirm current operation or environmental outcomes.
Working method
Scope is built from the operation toward the technology, not from an isolated list of functions.
01
Objective, people, space, constraints, and the task worth understanding.
02
Required hardware, software, data, energy, connectivity, and interaction.
03
Routes, responses, and touchpoints to review before deployment.
04
Configuration, installation, support, and further adjustments defined by proposal.
PUDU catalog
The product sheets bring together authorized media and technical data. Configuration, purchase, or rental is discussed according to the space and operation.
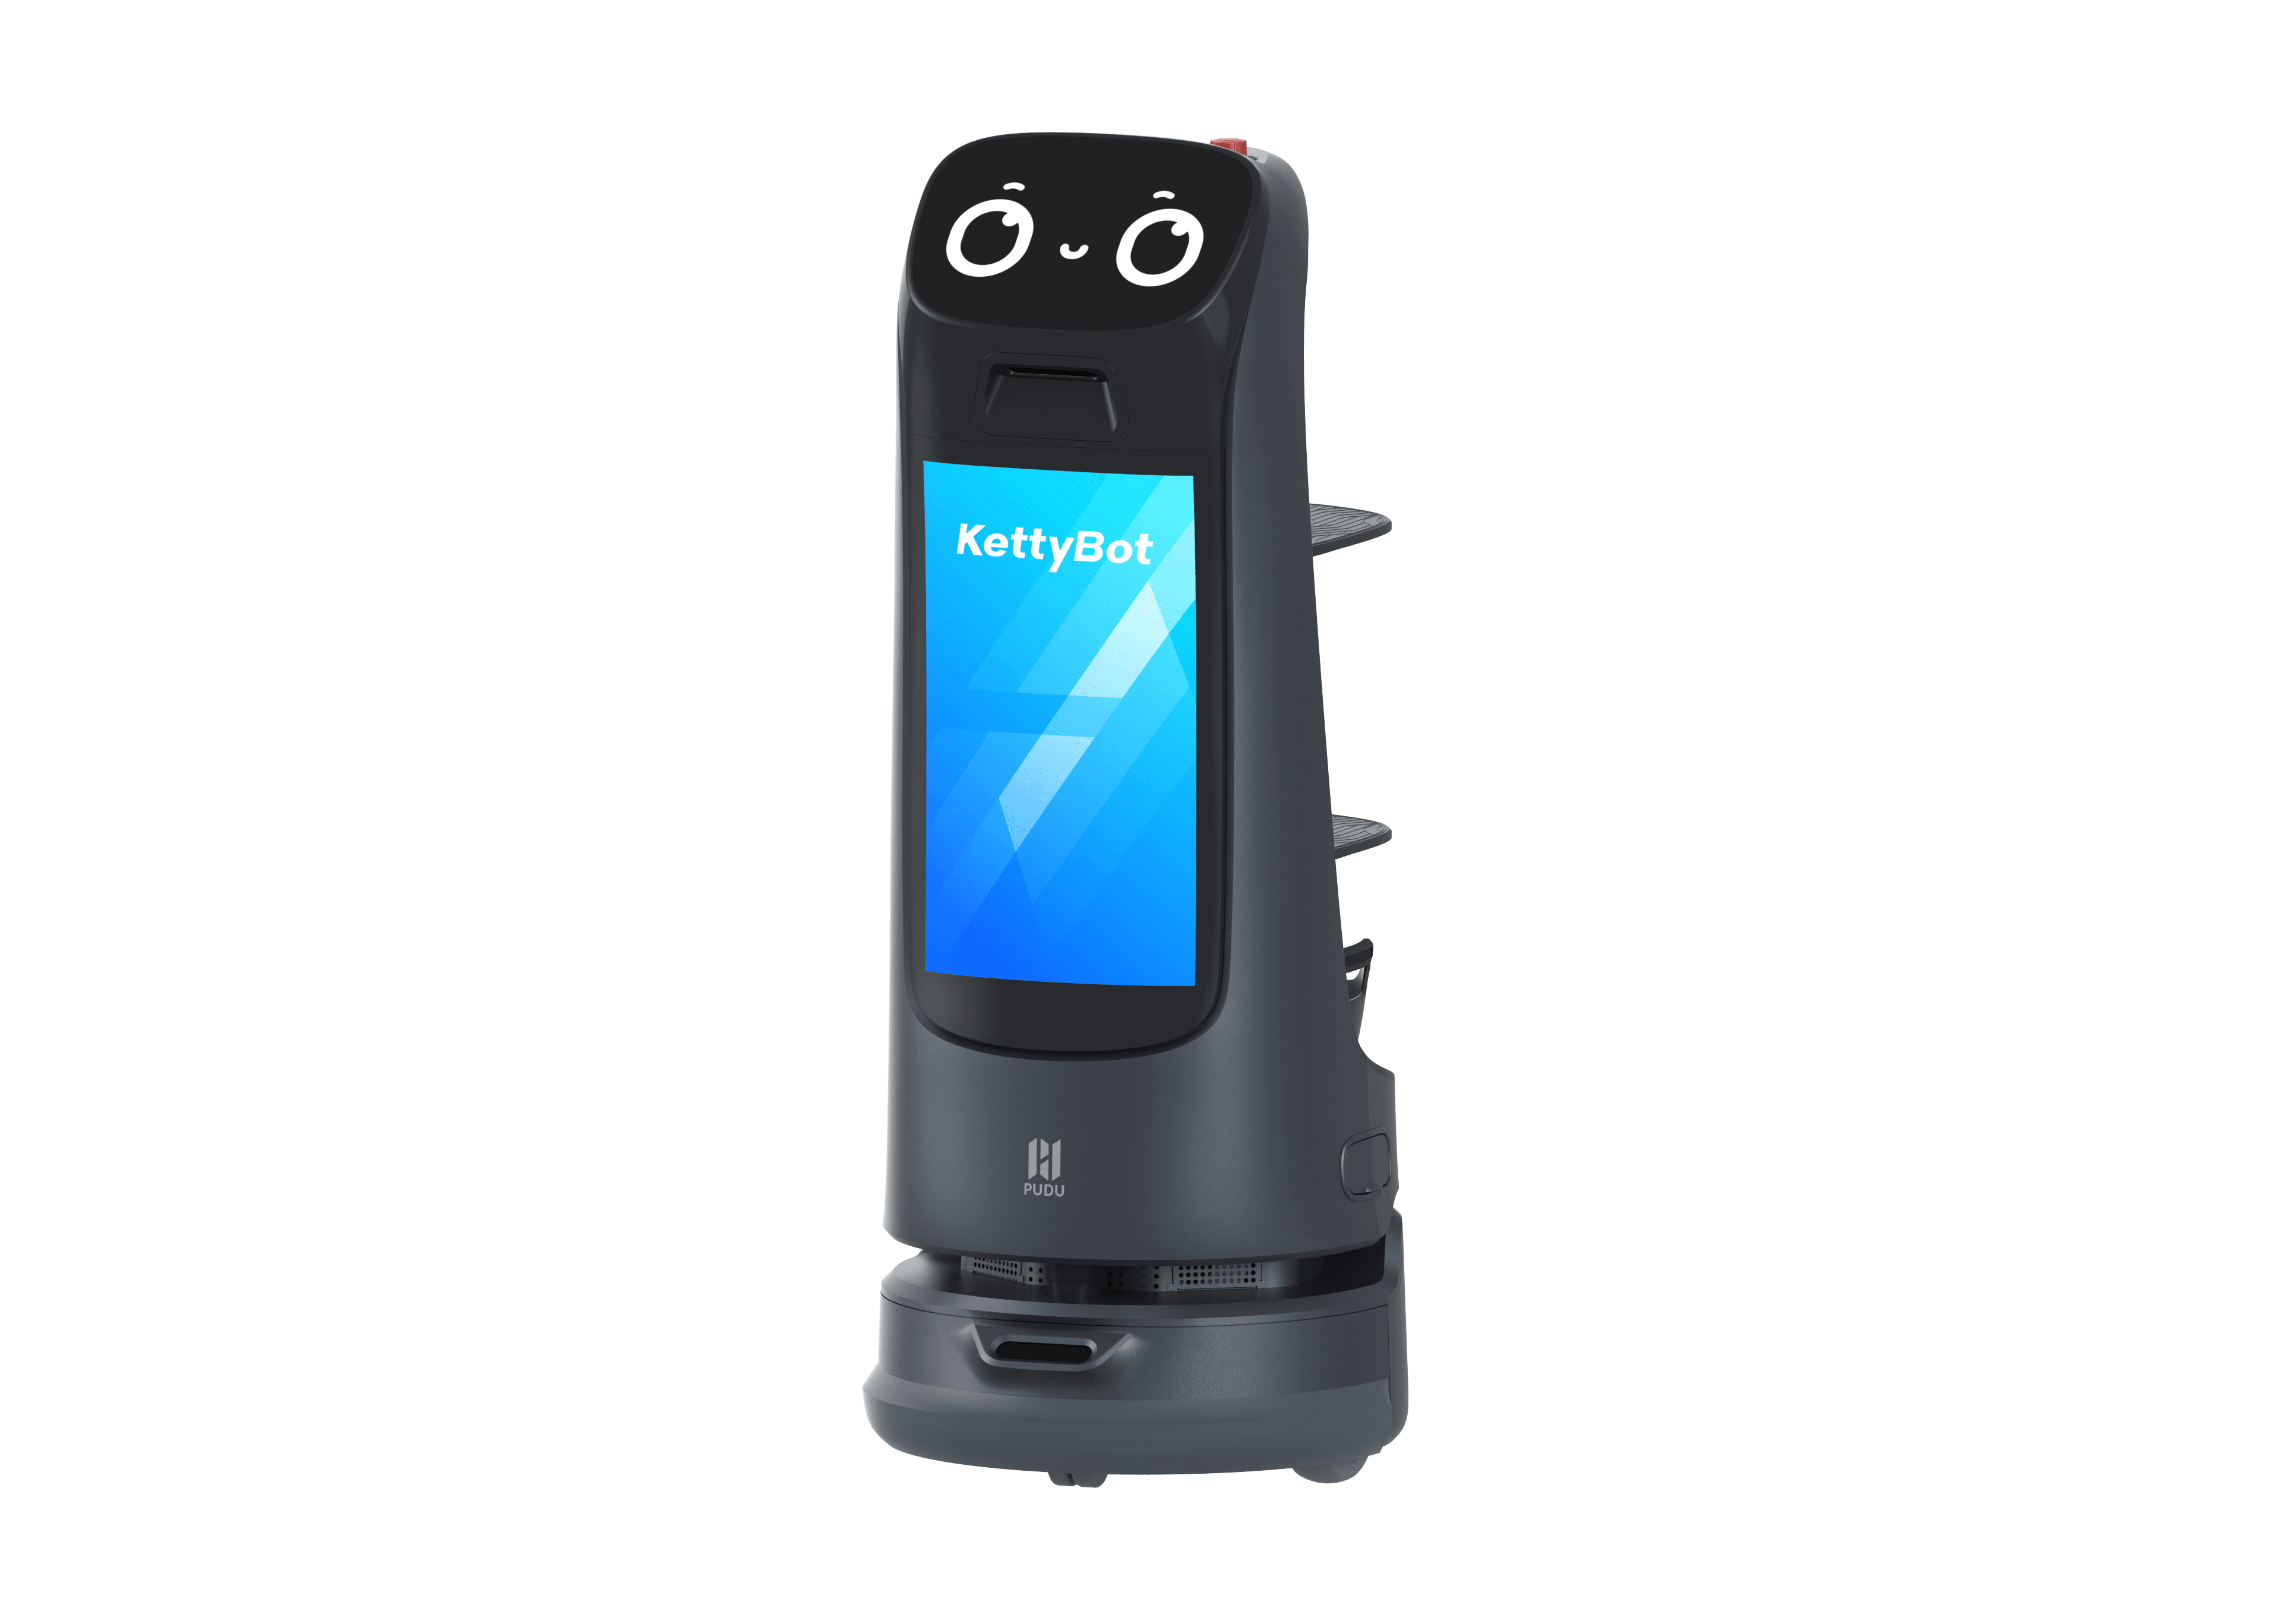
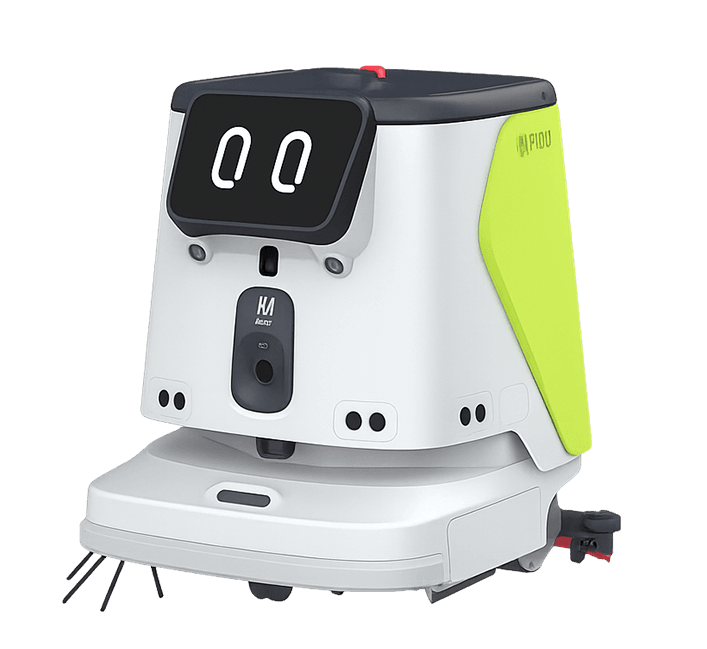
A cleaning robot for sweeping, vacuuming, dust mopping, and scrubbing.
View technical sheet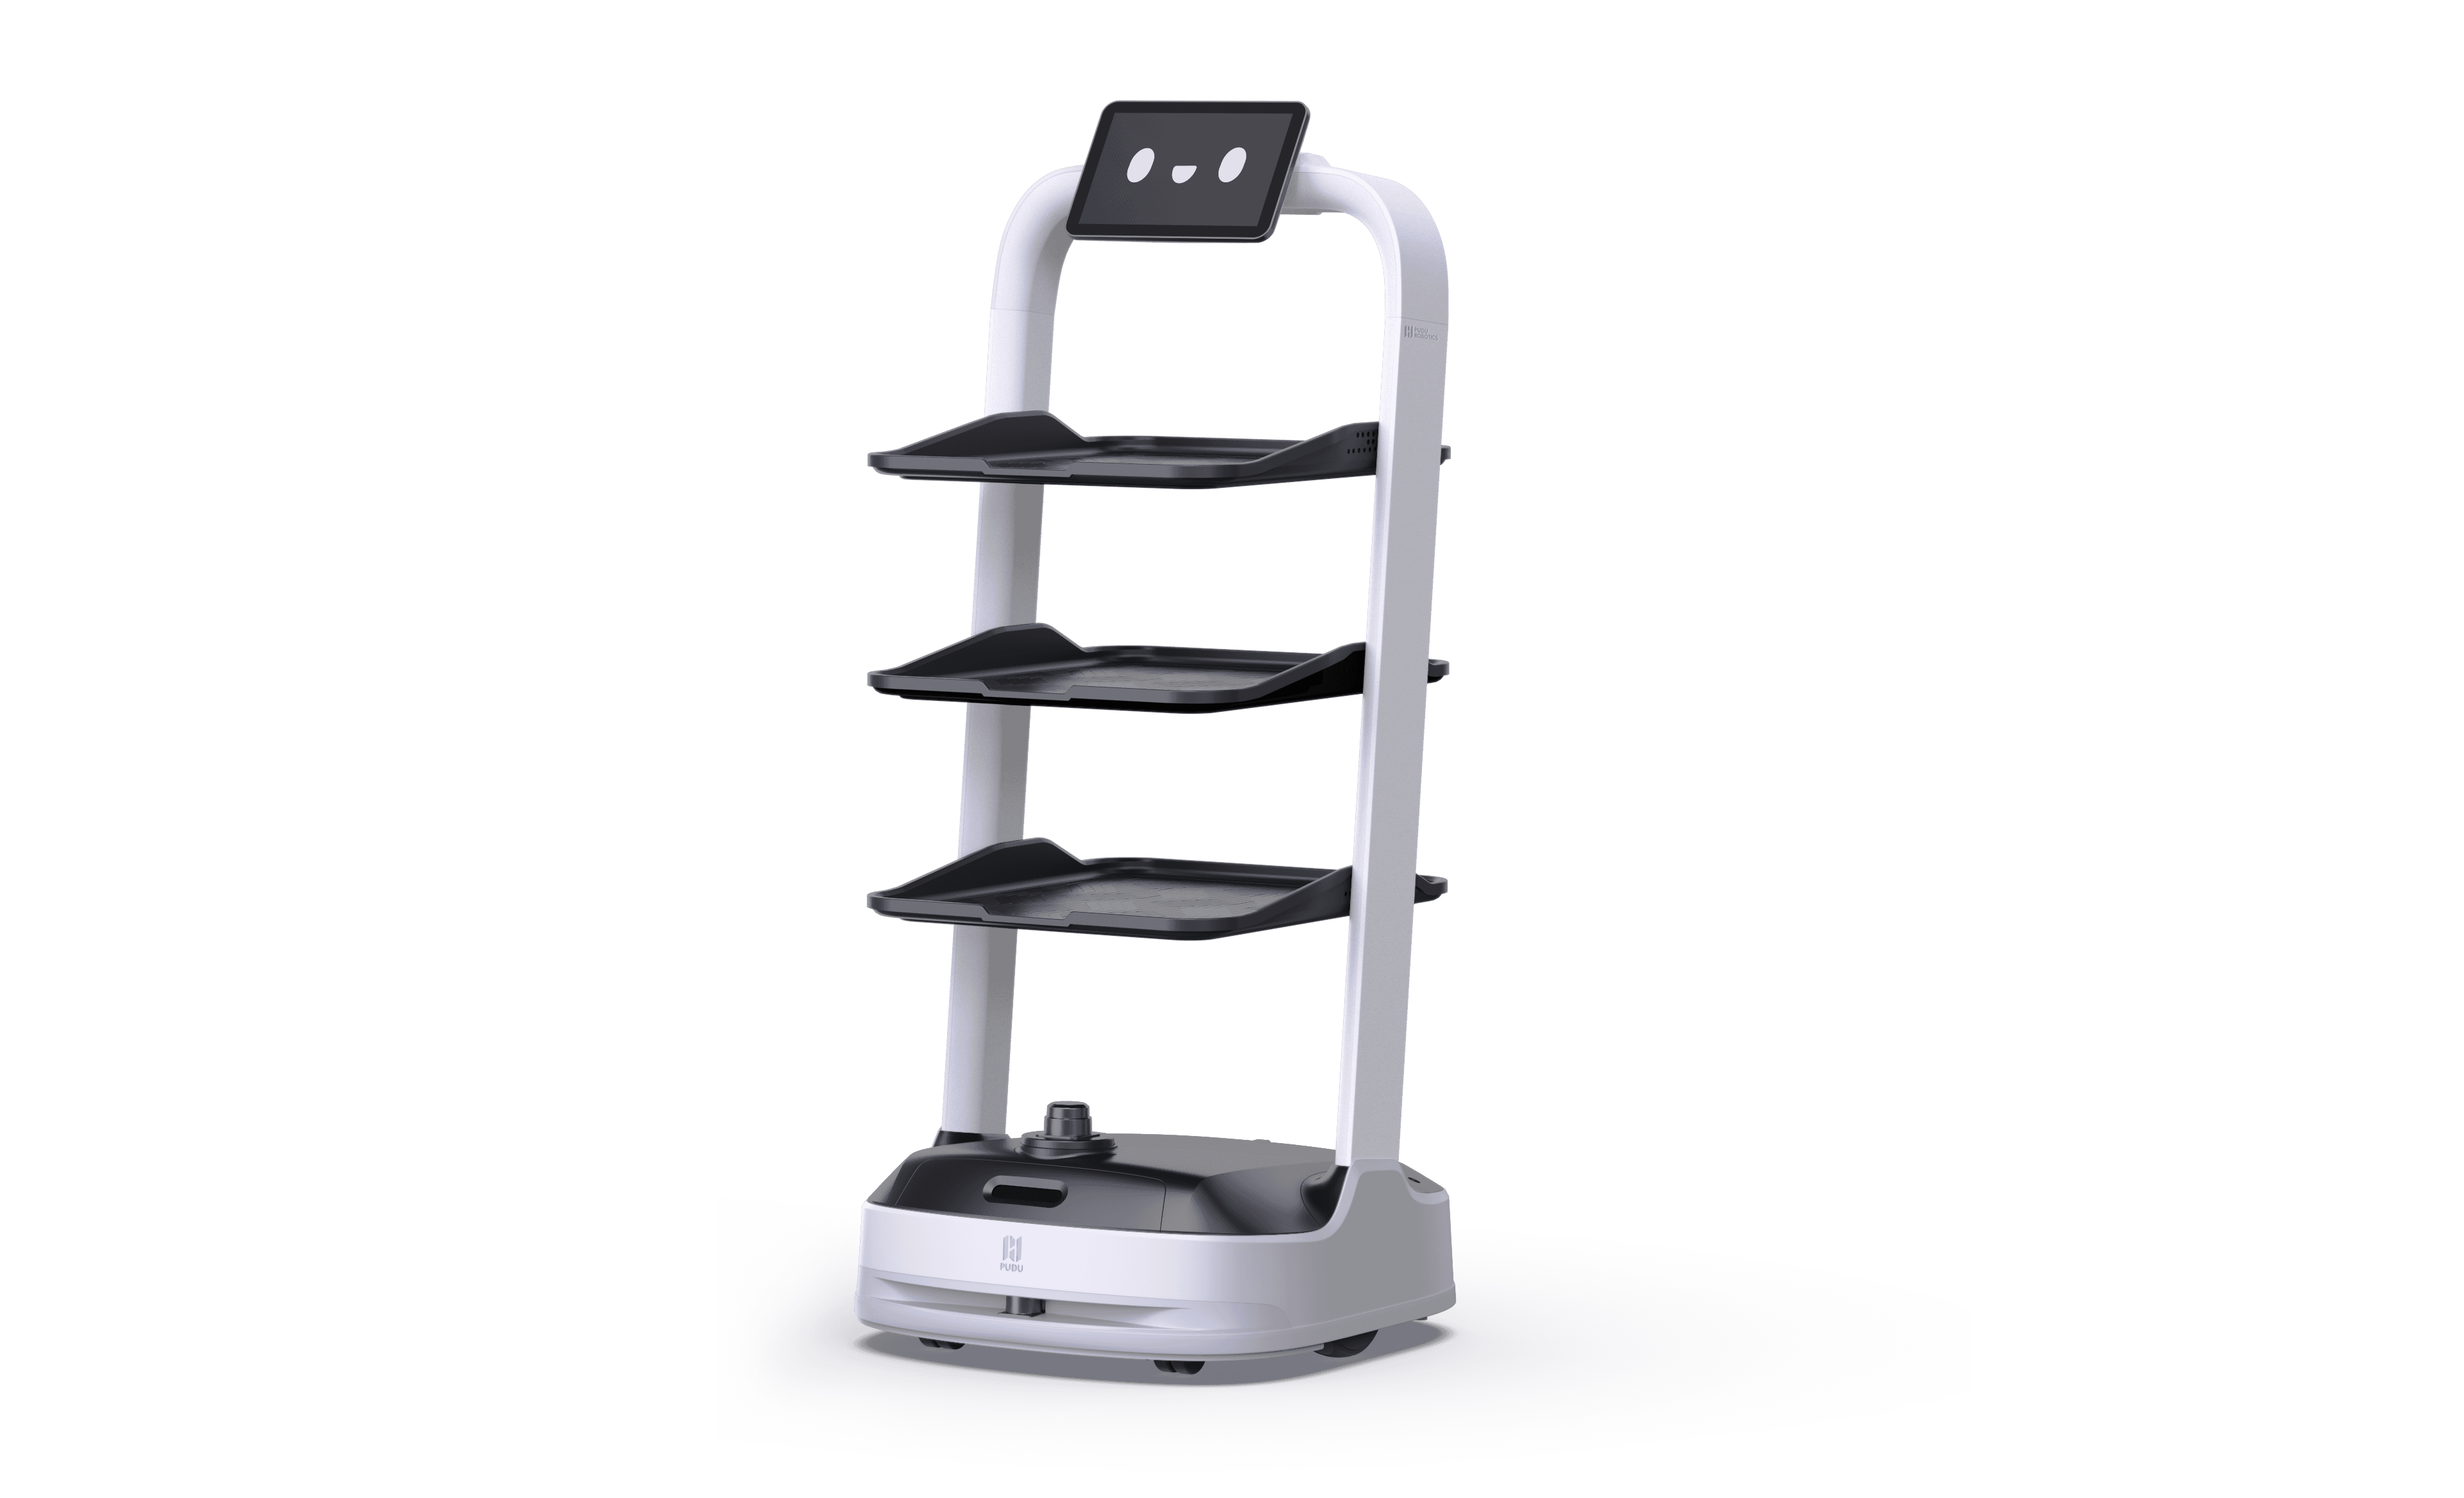
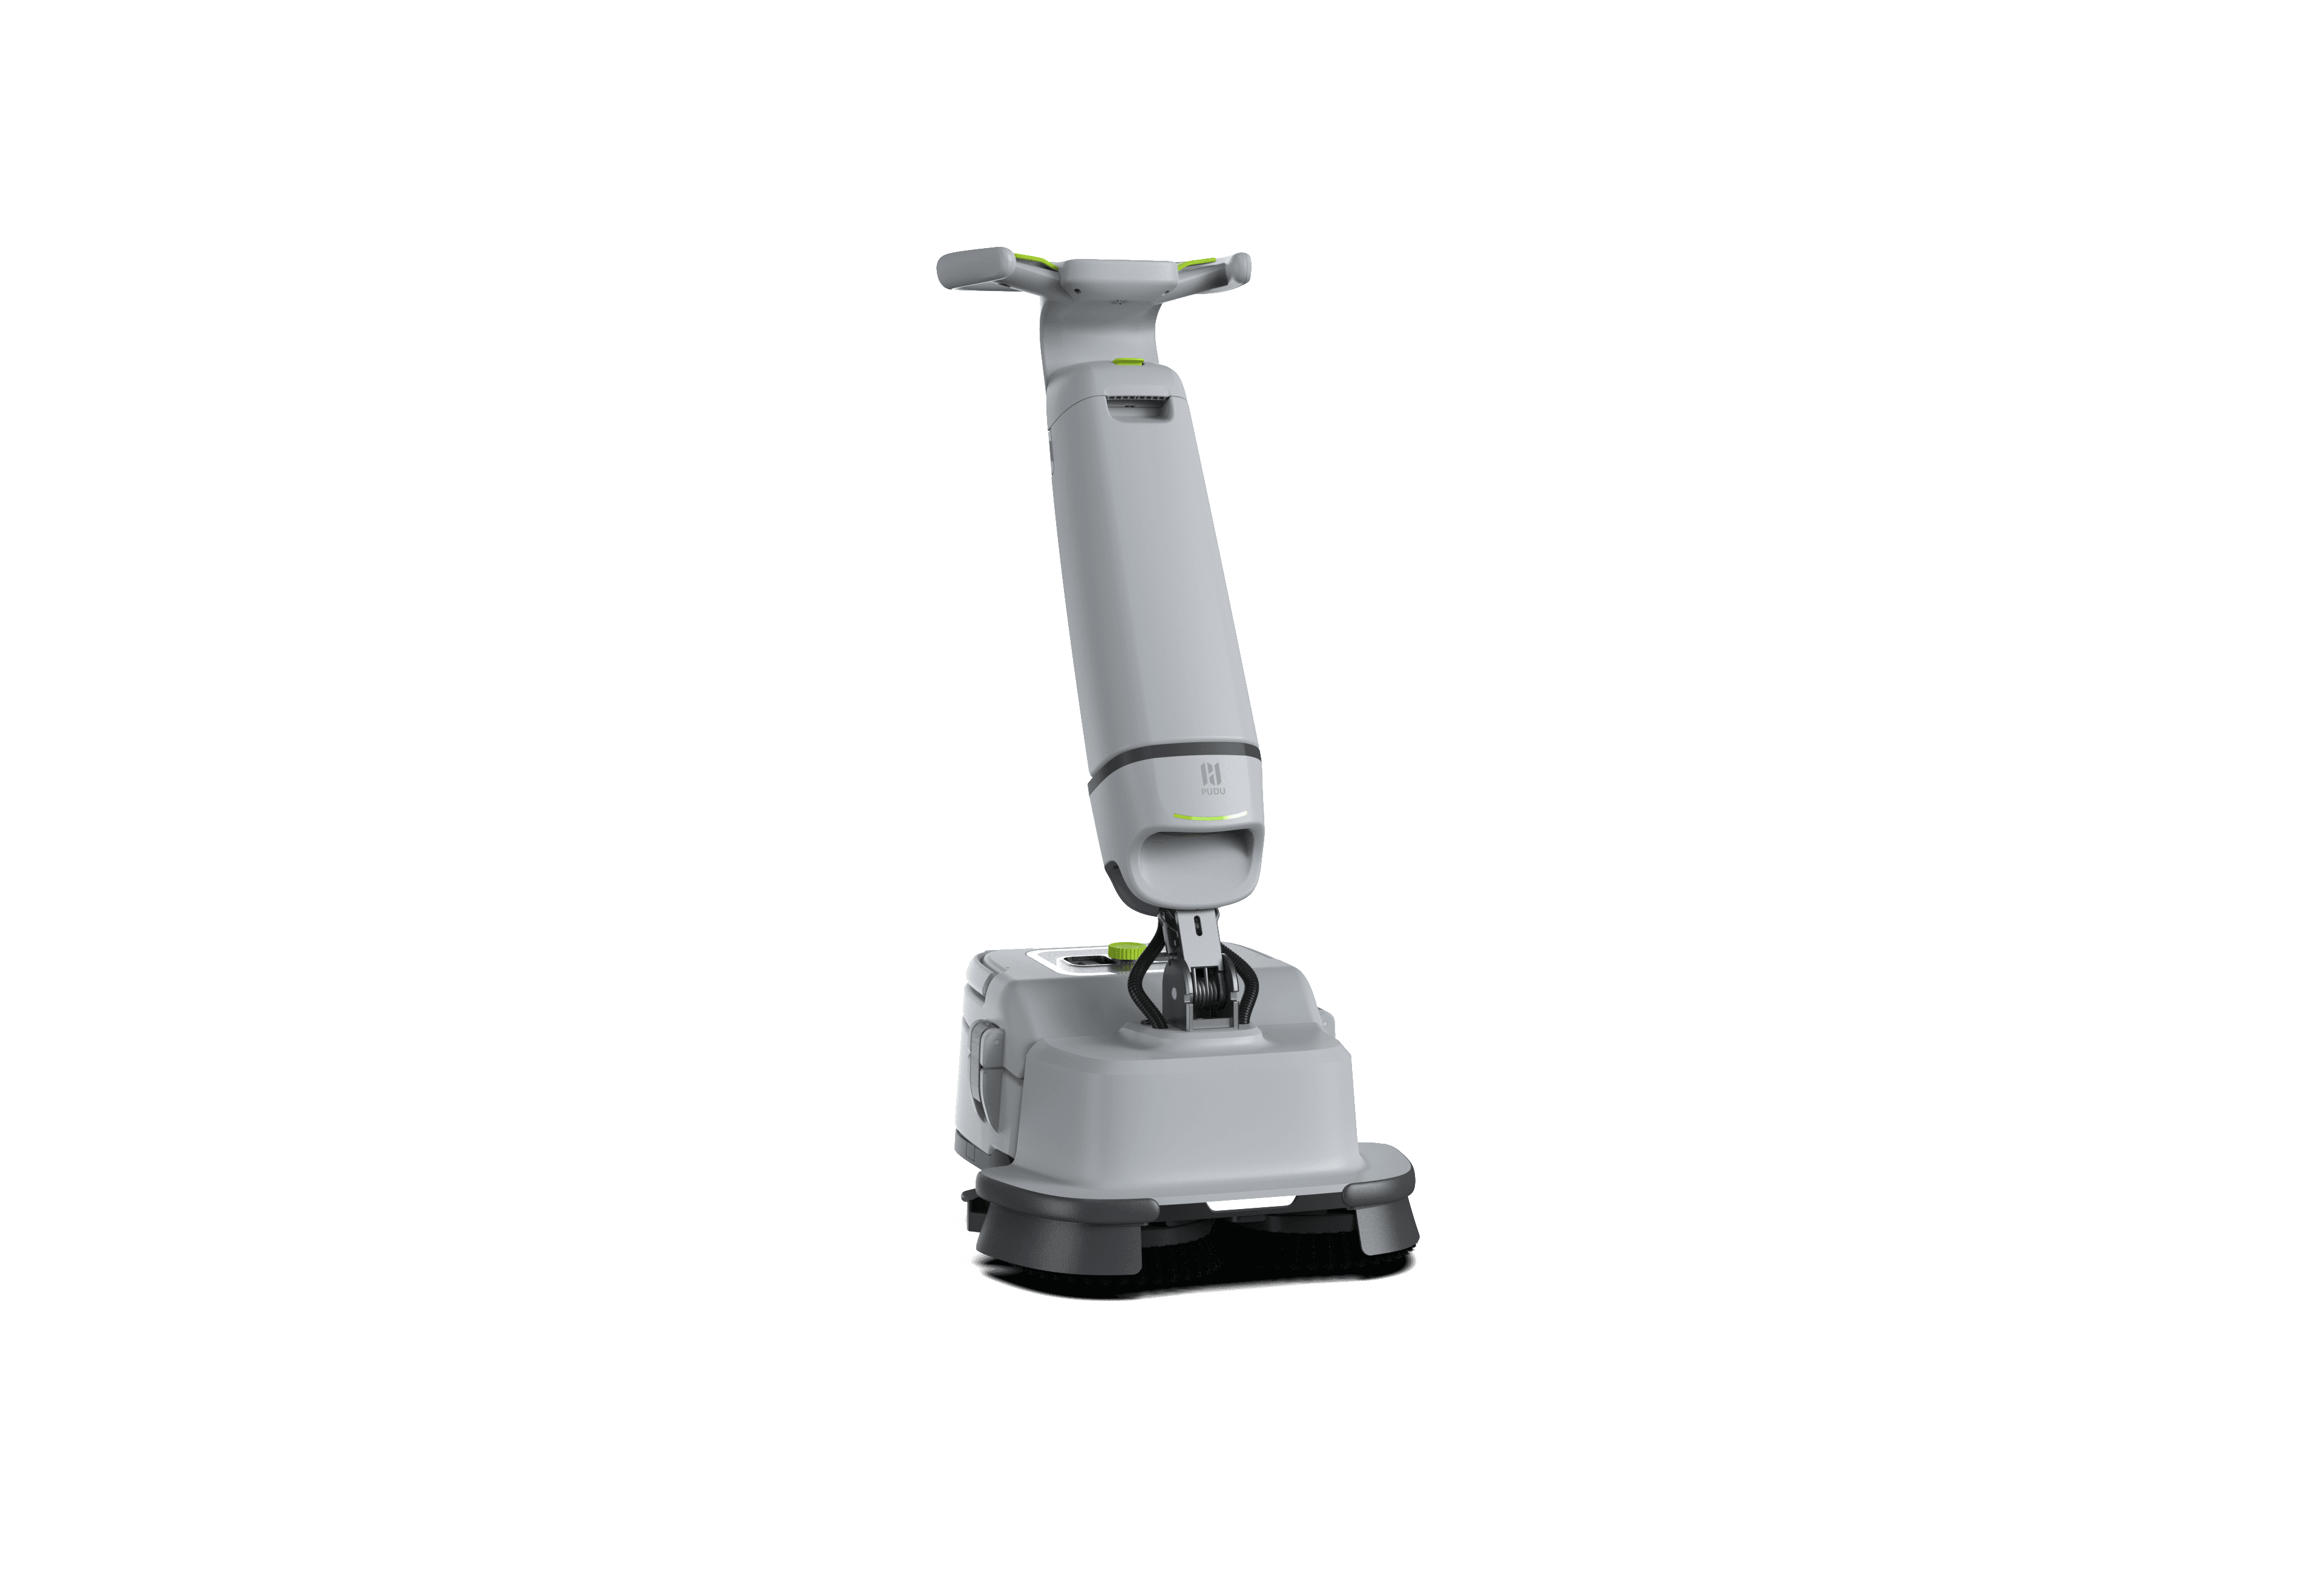
A compact machine for floor and surface cleaning with specialized accessories.
View technical sheet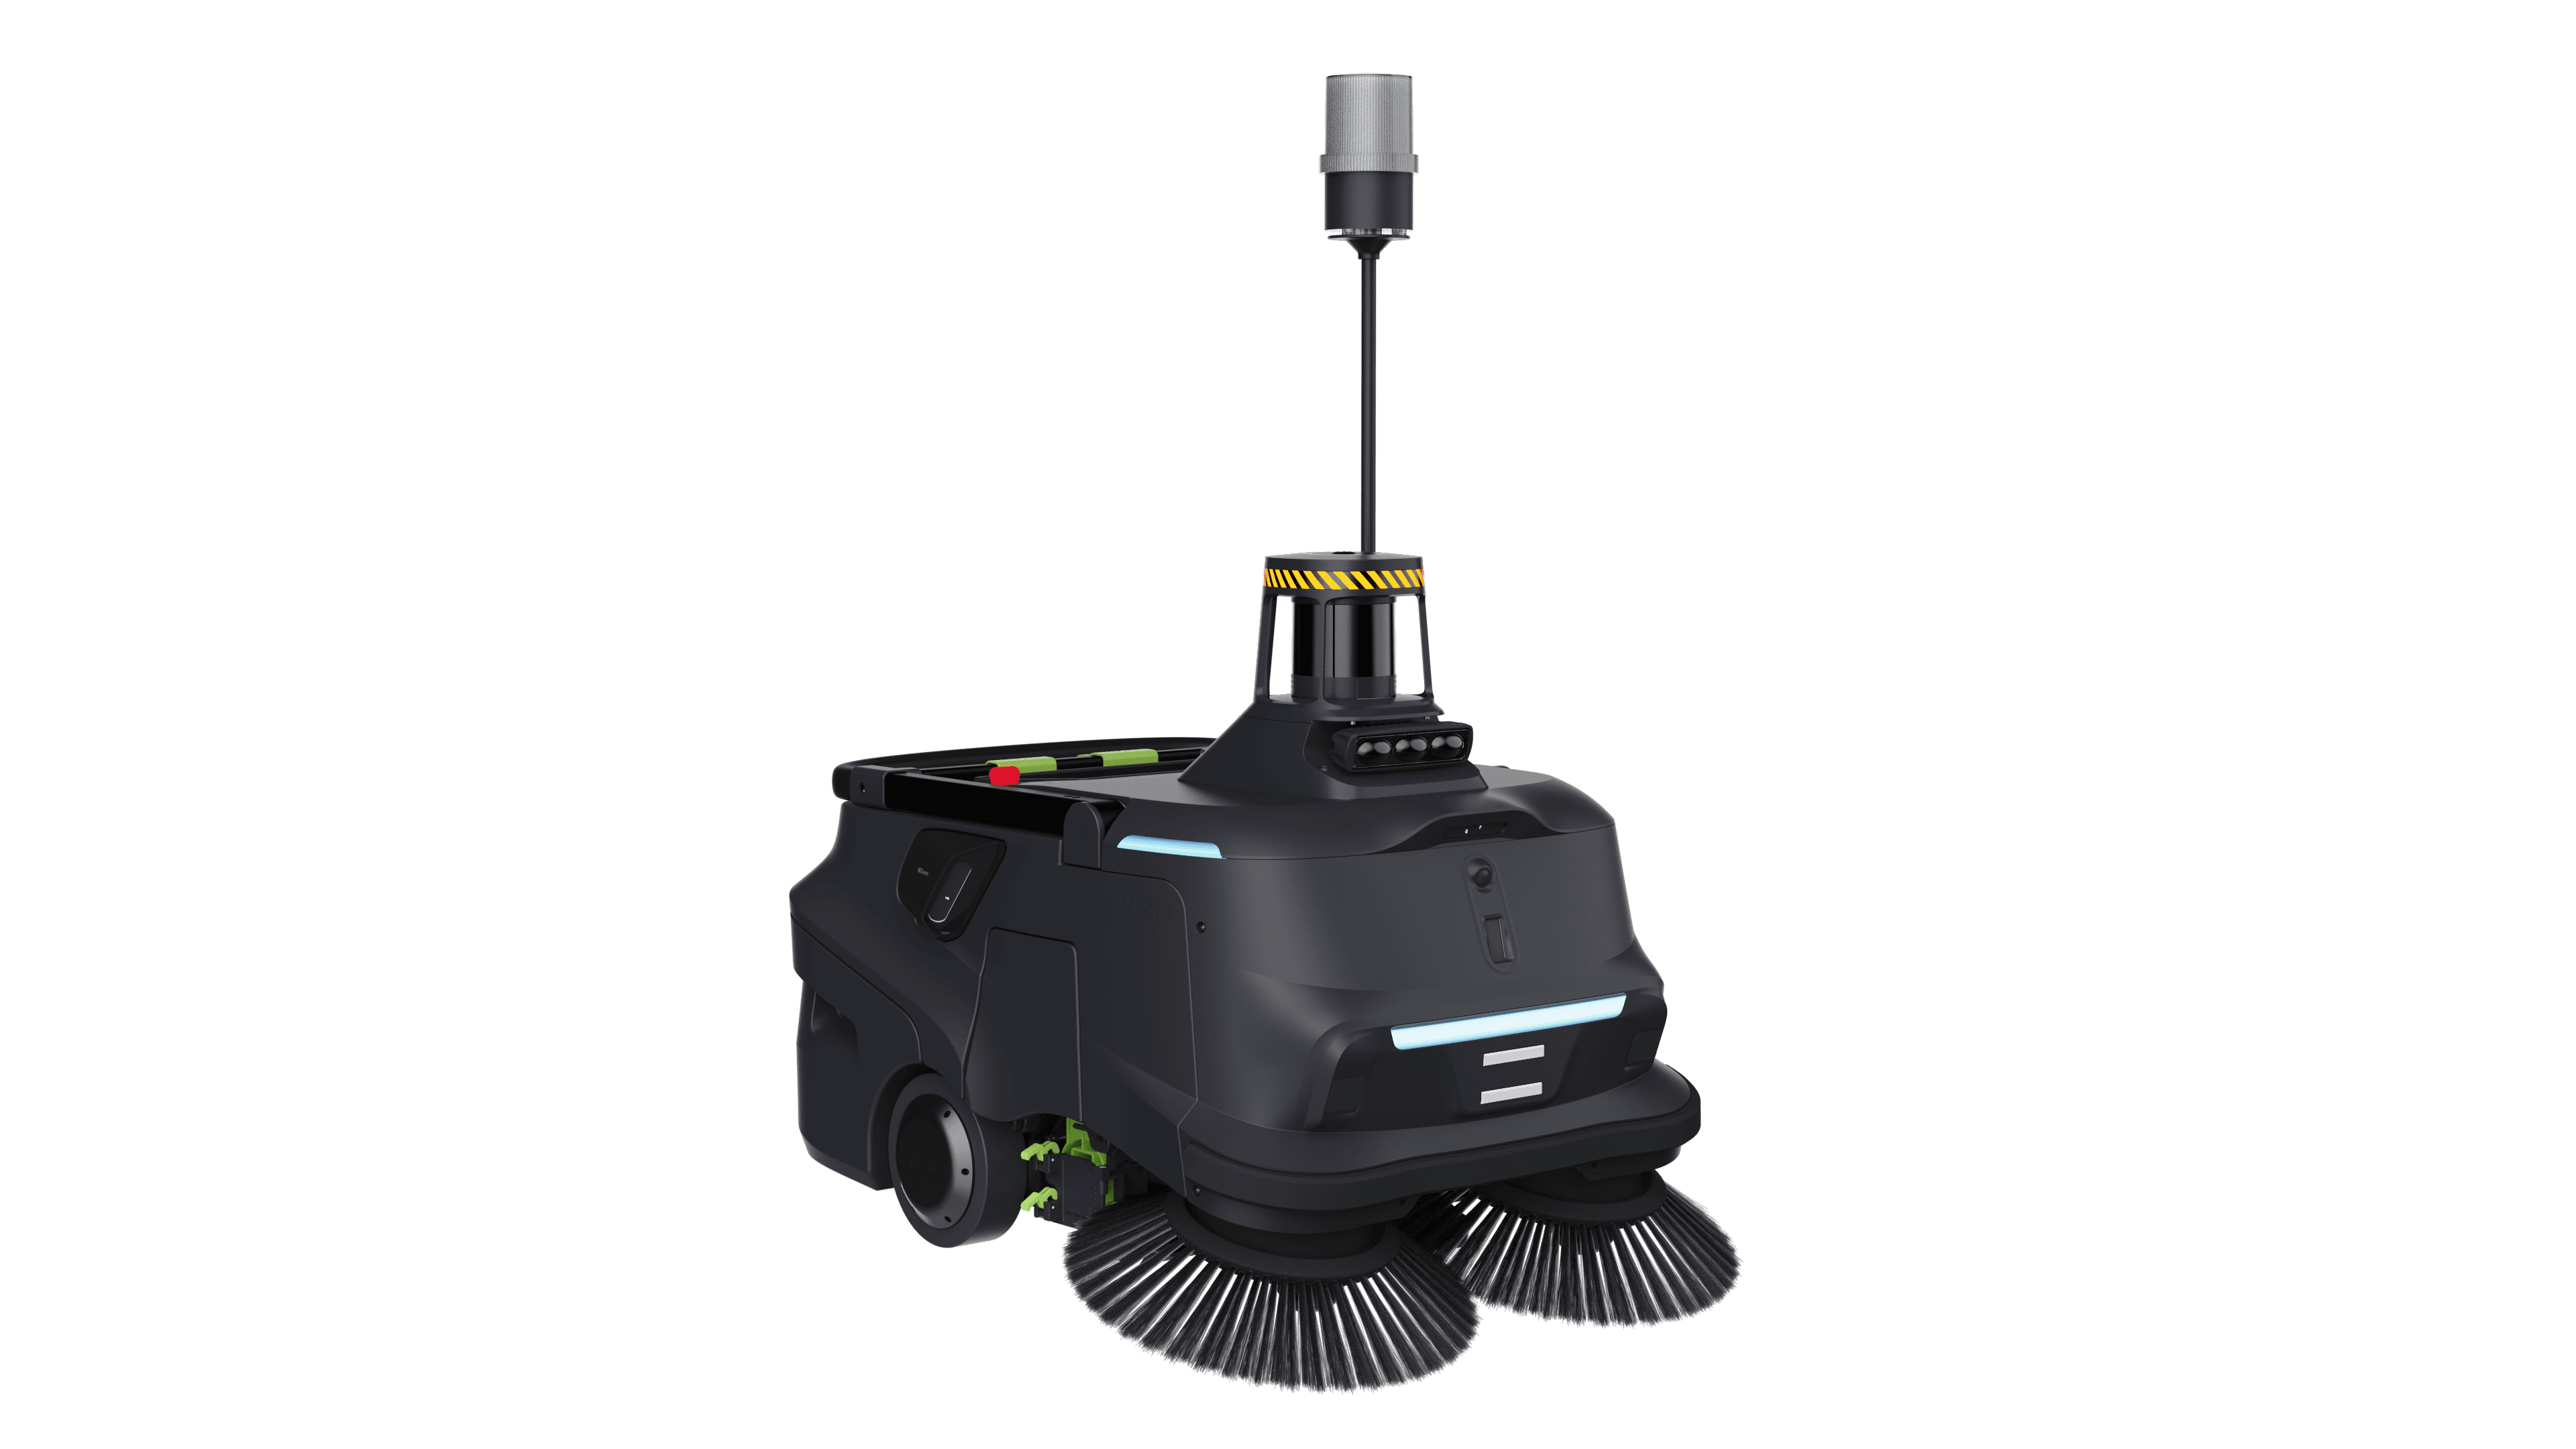
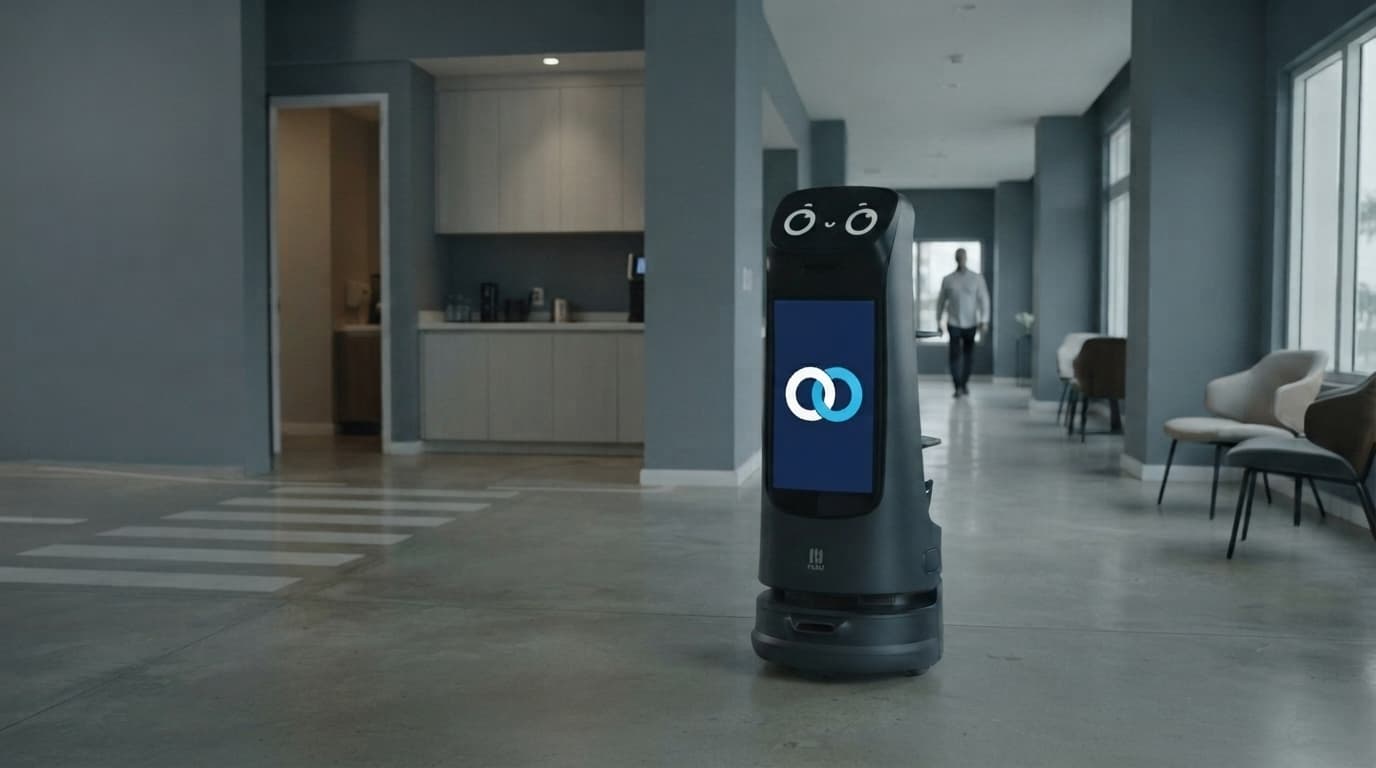
Robotics in context
Circulation, visibility, crossings, waiting, charging, and interaction change how a robot should be evaluated. A documentary scene helps frame those questions without turning it into proof of performance.
Starting point
We can start with the task, space, and people who interact with it; then define which product, prototype, or integration is worth evaluating.